대표 논문
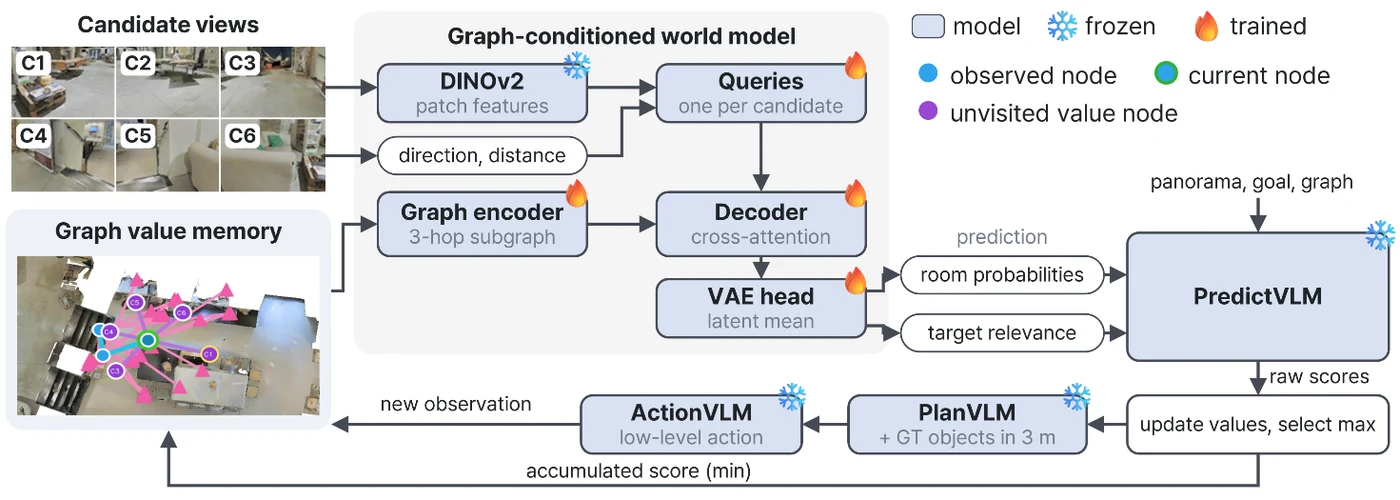
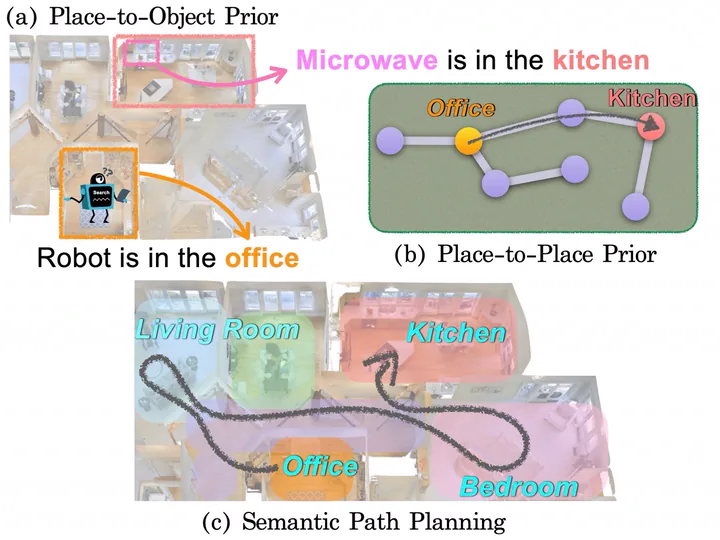
A Graph-Based World Model for Object Goal Navigation
Journal of Institute of Control, Robotics and Systems, 32(11), 2026 (accepted).
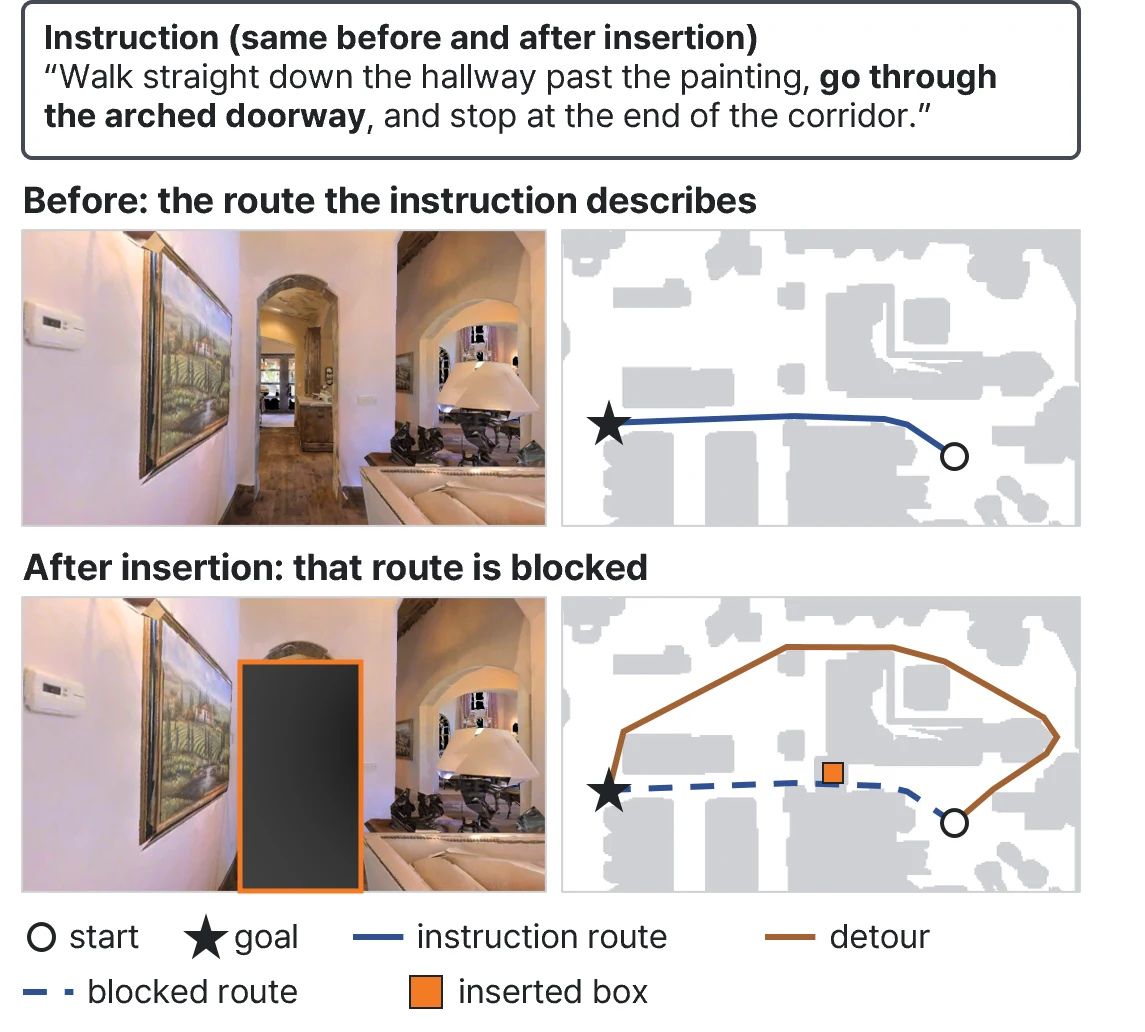
ChangeVLN: A Benchmark for Vision-Language Navigation in Changed Environments
First Workshop on Semantic-Aware Mapping and Navigation: Towards Cognitive and Adaptive Robots (SeMaNa), IROS 2026 Workshop.